Phased array ultrasonic testing (PAUT) is a pulse-echo ultrasonic method that fires a group of small transducer elements with programmed time delays, called a focal law, so the beam can be steered and focused without changing probe. A typical weld S-scan sweeps 40° to 70° in 1° steps, which is 31 focal laws per scan position.
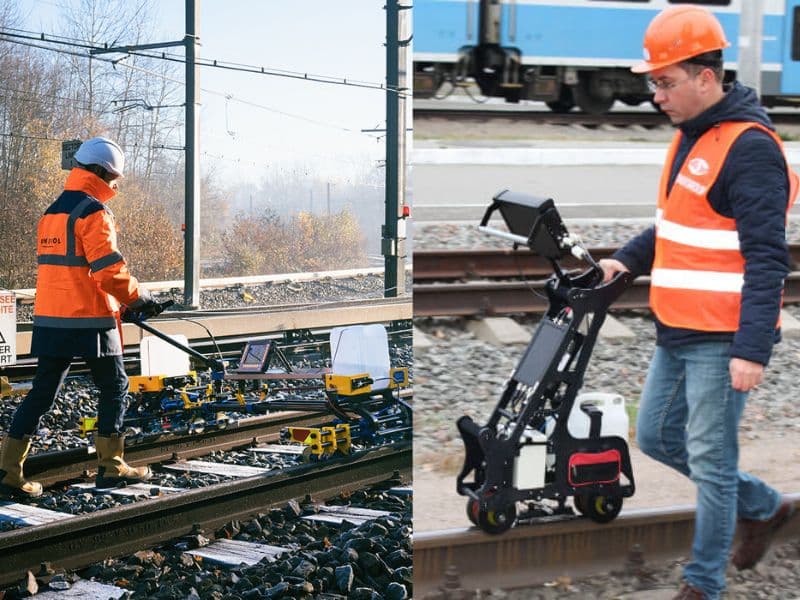
The method is written into weld codes such as ASTM E2700-26, ISO 13588 and the phased array appendices of ASME Section V, Article 4. In rail, phased array ultrasonic testing is used for weld work, defect verification and research test vehicles. It is not the routine method behind most federally required rail flaw testing.
This page is the fundamentals hub: how the beam is formed, how a system is calibrated, which documents govern it, and where it is and isn't used on railroads. Linked pages cover the narrower comparisons.
Contents: What PAUT is · Beam forming · E-scan and S-scan · Focusing · Worked example · FMC/TFM · Calibration · Codes · Rail use · Limits · Scan plans · FAQ
What is phased array ultrasonic testing?
Phased array ultrasonic testing is conventional pulse-echo UT with an electronically controlled beam. Instead of one piezoelectric element fixed to a wedge of one angle, the probe holds a row of small elements, commonly 16, 32, 64 or more. The instrument fires a chosen group of them with delays measured in nanoseconds, and the wavefronts add up into one beam at the angle and depth the delays set.
The physics of the echo is unchanged. Sound still reflects from a crack, lack of fusion or porosity, and the instrument still measures time of flight and amplitude. What changes is that one probe position can produce many beams, and the system records them together, usually with an encoder giving position along the weld.
That gives three practical differences from a single-element probe:
- Several angles from one probe. A sweep from 40° to 70° replaces a set of 45°, 60° and 70° wedges.
- An image, not only an A-scan. The stored A-scans are plotted as a sector or rectangle, so the analyst sees reflectors in a cross-section of the weld.
- A permanent record. Encoded data can be re-analyzed later, audited, or compared with a repair scan.
PAUT is still a contact (or immersion) method. The probe must be coupled to the part and moved along the weld or rail, and the image is only as good as the setup behind it. For a side-by-side comparison with single-element UT, see UT vs PAUT.
Key takeaway: phased array changes how the beam is formed and recorded, not what the sound can physically detect.
How does a phased array probe form and steer a beam?
A phased array probe steers and focuses by delaying each element's firing so the individual wavefronts arrive in step along the wanted direction. The set of delays for one beam is the focal law (also called a delay law). The instrument stores one focal law for every beam it fires.
Three probe dimensions control what the beam can do. Evident's probe tutorial defines pitch as "the distance between individual elements" and the aperture as the effective size of the group fired together. It also notes that "most standard instruments will support apertures of up to 16 elements", with advanced systems running 32 or 64.
| Term | What it means | Why it matters |
|---|---|---|
| Element | One piezoelectric strip in the array (modern NDT arrays are mostly piezocomposite) | Element width sets how widely each element radiates |
| Pitch (p) | Center-to-center spacing of elements | Too large a pitch for the wavelength creates grating lobes |
| Active aperture (A) | Number of elements fired × pitch | Sets the near field, and so how deep the beam can be focused |
| Elevation | Element length across the array | Sets beam width in the passive plane, which electronics can't change |
| Focal law | The delay for each element in one beam | One law = one beam angle, position or focal depth |
| Wedge | Plastic block that sets the base incidence angle | Adds sound path, attenuation and a delay the instrument must subtract |
Steering uses a linear delay ramp. To tilt the beam by angle θ in the medium the elements touch, each element fires later than its neighbor by
Δt = p · sin θ / v
where v is the sound velocity in that medium (the wedge, for a wedge-mounted probe). Focusing adds a curved delay profile on top of the ramp, so the outer elements fire first and the center elements last.
Evident's tutorials make the design trade-off plain: "To optimize steering range, pitch must be small", while strong focusing needs a large aperture. With a fixed number of channels, those two demands pull against each other.
Key takeaway: every PAUT image is built from focal laws, and the probe's pitch and aperture limit which focal laws are physically sensible.
What is the difference between an E-scan and an S-scan?
An E-scan (linear or electronic scan) moves a beam of fixed angle along the array; an S-scan (sectorial scan) sweeps the beam through a range of angles from one aperture. Most weld work uses one or both, and ASTM E2700 names them directly: the practice "uses angle beams, either in S-scan or E-scan modes, primarily for butt welds and tee welds".
| Feature | E-scan (linear) | S-scan (sectorial) |
|---|---|---|
| How it works | The same focal law is stepped along the array, one element at a time | One aperture fires a series of angles |
| Typical display | Rectangular cross-section | Fan-shaped sector |
| Typical use | 0° plate and corrosion mapping; fixed-angle weld scans; zone coverage | Weld volume coverage from one probe offset |
| Focal-law count (example) | 16-element aperture on a 64-element probe, stepped by 1 = 49 laws | 40° to 70° at 1° steps = 31 laws |
| Main risk | Coverage depends on the one angle chosen | Amplitude varies with angle; needs angle-corrected gain |
The two can be combined. A common weld setup runs an S-scan from each side of the weld while an encoder records travel along it, so every stored A-scan has an angle, an index position and a scan position.
A sweep is not automatic coverage. In an earlier EMA worked example on a 1 in. single-V weld, a 40° to 70° S-scan from one probe offset missed about 26% of the weld plus heat-affected zone; two offsets were needed. The scan plan, not the sweep range, decides coverage.
Key takeaway: E-scans move the beam, S-scans turn it, and neither replaces a drawn scan plan.
How does phased array focusing work, and where does it stop?
A phased array can focus the beam only inside the near field of its active aperture. Beyond that distance the beam is already at its natural narrowest, and the focusing delays have little effect.
For a rectangular aperture the near field is approximately N = A²f / 4v. A 16-element, 0.6 mm pitch aperture (9.6 mm) at 5 MHz in steel with longitudinal waves (5.92 mm/µs) gives N of about 19.5 mm. Asking that aperture to focus at 30 mm only produces a beam that looks focused on the setup screen.
Wedge-mounted shear-wave probes lose part of the near field inside the wedge. An earlier EMA calculation for a 16-element aperture on a 20 mm acrylic wedge path left only about 34 mm of near field in steel, roughly 17 mm deep at 60°. Doubling the aperture to 32 elements pushed it past 120 mm.
Practical focusing rules that follow from this:
- Check the focal depth against the active aperture's near field after the wedge deduction. A focal depth beyond it is a setup error.
- Use a larger aperture for deeper focus, accepting fewer E-scan steps or a coarser sweep for the same channel count.
- Focusing narrows the beam only near the focal depth. Above and below it the beam widens again, which matters for length sizing by amplitude drop.
Key takeaway: a focal law can't focus past the near field, so focal depth must be checked against aperture, frequency and wedge path.
Worked example: focal-law delays and grating lobes for a linear array
This worked example computes real focal-law delays and checks pitch against grating lobes, using a common 5 MHz linear array. The inputs are illustrative, chosen to match typical weld probes; your probe's data sheet and the instrument's calculator govern a real setup.
Inputs: 5 MHz linear array, 16 active elements, 0.6 mm pitch. Wedge: acrylic, longitudinal velocity 2.73 mm/µs, cut at 36° (refracts to about 44.4° shear in steel). Steel shear velocity 3.25 mm/µs; steel longitudinal velocity 5.92 mm/µs.
Part 1: steering delays for a 40° to 70° S-scan
Snell's law gives the incidence angle needed in the wedge for each refracted angle: sin α = (2.73 / 3.25) · sin β. The array face is tilted at the 36° wedge angle, so the steering angle relative to the array is α − 36°. Each element's delay step is then 0.6 · sin(α − 36°) / 2.73 µs.
| Refracted shear angle in steel (β) | Incidence in wedge (α) | Steering from array normal | Delay step per element | Delay across 16 elements (15 steps) |
|---|---|---|---|---|
| 40° | 32.7° | −3.3° | −12.7 ns | −0.191 µs |
| 45° | 36.4° | +0.4° | +1.7 ns | +0.025 µs |
| 55° | 43.5° | +7.5° | +28.6 ns | +0.429 µs |
| 60° | 46.7° | +10.7° | +40.7 ns | +0.611 µs |
| 70° | 52.1° | +16.1° | +61.0 ns | +0.916 µs |
The negative values at 40° mean the firing order reverses: the beam is steered back toward the wedge normal, so the opposite end of the aperture fires first. Near 45° almost no delay is needed, because the wedge alone already produces about that angle.
Real focal-law calculators add two more terms: a focusing curve and a correction for each element's height above the steel (elements on an inclined wedge sit at different distances from the part). The steering ramp above is the largest term and the easiest to check by hand.
Part 2: focusing delays at 10 mm depth
For the same 16-element aperture in direct contact with steel (longitudinal waves, no wedge, focus straight below the array center at F = 10 mm), each element's delay is the path difference to the focal point divided by velocity: Δtᵢ = (√(F² + x_max²) − √(F² + xᵢ²)) / v.
| Element (from one end) | Distance from aperture center | Delay |
|---|---|---|
| 1 | 4.5 mm | 0 ns (fires first) |
| 2 | 3.9 mm | 39.2 ns |
| 4 | 2.7 mm | 102.7 ns |
| 6 | 1.5 mm | 144.3 ns |
| 8 | 0.3 mm | 162.4 ns (fires last) |
The pattern is symmetrical, so elements 9 to 16 mirror 8 to 1. The 10 mm focus sits inside the aperture's 19.5 mm near field; a 25 mm focus would not.
Part 3: is 0.6 mm pitch small enough?
A grating lobe is a second, unwanted beam that appears when pitch is large compared with the wavelength. By standard array physics it points at sin θ_g = sin θ_s − m·λ/p (m = ±1, ±2 …) and exists whenever that value lies between −1 and +1. The array is free of grating lobes up to a steering angle θ_max when p < λ / (1 + sin θ_max). This matches the NTNU course note: "An array pitch equal to λ/2 guarantees the absence of grating lobes under any focusing and steering condition", and a pitch of λ is enough with no steering.
For longitudinal waves in steel at 5 MHz, λ = 5.92 / 5 = 1.18 mm.
| Pitch | p / λ | Steering without grating lobes | Grating lobe when steered to 45° |
|---|---|---|---|
| 0.6 mm | 0.51 | up to about 77° | none |
| 1.0 mm | 0.84 | up to about 11° | yes, near −28° |
| 1.5 mm | 1.27 | none (a lobe exists even unsteered, near 52°) | yes, near −5° |
The 0.6 mm pitch is close to λ/2 in steel and steers cleanly. The wedge is a different medium, though. In acrylic the wavelength at 5 MHz is only 0.55 mm, smaller than the 0.6 mm pitch, so the simple relation predicts a grating lobe inside the wedge: at the 60° law it points about 46° to the other side of the array normal.
Element directivity and the probe's bandwidth weaken such lobes, and wedges carry damping, so the real question is how strong the lobe is. That is answered by modeling the probe and wedge pair and checking the beam on a block, not by the formula alone.
Key takeaway: compute the steering ramp, check focal depth against the near field, and check pitch against wavelength in every medium the beam is steered in.
What are FMC and TFM?
Full matrix capture (FMC) records every transmit-receive pair in the array, and the total focusing method (TFM) uses that data to focus at every point in an image grid. With 64 elements, FMC stores 64 × 64 = 4,096 A-scans per probe position, against one per focal law in conventional PAUT.
TFM images can be sharper over the whole region of interest, but the data sets and processing are larger, and the image still depends on velocity, geometry and the wave modes chosen. Two ISO standards cover it. ISO 23865:2021 gives general provisions for FMC/TFM, and ISO 23864:2021 covers semi- or fully automated TFM testing of fusion-welded joints of 3.2 mm minimum thickness, with four testing levels and no acceptance levels.
In ASME Section V, an FMC appendix was reported added to Article 4 in 2019, and a secondary summary of the 2025 edition says FMC requirements moved to Article 3. Both points come from secondary sources, so confirm them in the edition your contract names.
Key takeaway: FMC/TFM is an extension of phased array with its own ISO standards, not a different physical method.
How is a PAUT system calibrated before scanning?
A PAUT setup is calibrated in a fixed order: velocity and wedge delay first, then sensitivity across every focal law (ACG and TCG), then the encoder. Evident's calibration tutorial explains why the per-law step matters: "it is important to normalize the response from each focal law", to correct for element-to-element differences and for wedge attenuation that changes with angle.
| Step | What is checked | Typical method |
|---|---|---|
| Element check | No dead or weak elements in the active aperture | Instrument element-activity check, on a block or in couplant |
| Velocity | Sound velocity in the part material | Known radius or thickness on a block of the same material |
| Wedge delay | Time spent in the wedge, for every focal law | Sweep a known radius or side-drilled hole so all laws read the same depth |
| ACG (angle-corrected gain) | Equal amplitude at every angle of an S-scan | Peak one reflector through the full sweep and let the instrument level each law |
| TCG (time-corrected gain) | Equal amplitude with depth, per focal law | Peak side-drilled holes at several depths across all laws |
| Encoder | Displayed travel matches real travel | Move the probe a measured distance and compare |
| Check during and after | Setup unchanged | Re-scan the reference block at the intervals the procedure sets |
BINDT defines ACG as "a method of compensating for a reduction in signal amplitude with increases in beam angle" in S-scan mode. A reflector at one depth gives a weaker echo at 70° than at 45° because the path through the wedge and steel is longer, and ACG levels that out. TCG then corrects for distance, building one curve for each focal law.
Two points cause trouble in audits. First, many instruments can calibrate only one focal law at a time, so check that the whole sweep was calibrated, not just the center angle. Second, no public source gives the ASME Section V encoder tolerance, so the procedure must state the tolerance and the check distance it uses. For background on reference curves, see DAC curves in ultrasonic testing.
Key takeaway: a PAUT image is only as sound as its wedge delay, ACG, TCG and encoder checks, each recorded for the whole set of focal laws.
Which codes and standards govern phased array ultrasonic testing?
Phased array ultrasonic testing of welds is governed by technique documents (ASME Section V Article 4, ASTM E2700, ISO 13588), a system-evaluation guide (ASTM E2491), and separate acceptance criteria from the construction code or contract. Keeping those roles apart avoids the common error of quoting a technique practice as if it set reject levels.
| Document | Role | Key points (status checked October 2026) |
|---|---|---|
| ASME BPVC Section V, Article 4 | Weld UT technique, including PA appendices | Appendices reported as IV (manual raster with linear arrays), V (encoded E-scan and S-scan) and XI (FMC); numbering varies by edition, so confirm. No acceptance criteria |
| ASTM E2700-26 | Practice for contact PAUT of welds | S-scan or E-scan; mainly butt and tee welds; 9 mm to 200 mm, other thicknesses if shown on mockups. Active |
| ASTM E2491-23 | Guide to evaluating PA instrument and system performance | Sets no performance limits; uses test blocks and position encoders; "not intended to be used as a substitute for calibration". Active |
| ISO 13588:2019 | Semi- or fully automated PAUT of fusion welds | Minimum 6 mm; low-alloy or fine-grained steel (ISO 22825 adds rules for coarse-grained or austenitic); four testing levels; no acceptance levels. A revision is in development |
| ISO 19285 | PAUT acceptance levels | For indications classified under ISO 13588 in full-penetration ferritic welds 6 mm and thicker |
| EN ISO 23243:2020 | Vocabulary for testing with arrays | Replaced EN 16018 (terminology only) |
| AWS D1.1 (2020 and later) | Structural steel welding | Added a normative PAUT annex (Annex H in 2020); detail from vendor summaries, so confirm in the edition your contract names |
ASTM E2700 carries a warning that every scan plan reviewer should know:
"Extreme caution should be used when attempting to size indications using phased array. It is likely that without proper procedures, indications can be oversized due to beam divergence, multiple virtual probes returning signals from the same indication, etc." (ASTM E2700-26, section 1.2.1)
Secondary summaries of ASME V Appendix V report detailed requirements, for example an S-scan angular step of 1° or less (or at least 50% beam overlap), unprocessed A-scan storage and limits on data dropout. These are useful as a checklist, but confirm each value in your edition before writing it into a procedure. Acceptance comes from the referencing code: ASME VIII or B31.3, API 1104, the D1.1 annex, ISO 19285, or the owner's specification. See UT acceptance criteria and standards and ASME weld ultrasonic inspection.
Key takeaway: name the technique document and the acceptance document separately in every PAUT procedure.
Is phased array used for rail testing today?
Phased array is used in rail for weld examination, defect verification and research or optional test-vehicle systems, but it is not the routine method behind most US rail flaw testing. Under 49 CFR 213.237, track owners must perform internal rail inspections; the rule names no method, and the industry practice is conventional multi-channel UT from test cars, hi-rail trucks and carts.
The AAR's research arm described the conventional baseline in 2016. Its digest TD-16-030 says conventional cars "use piezoelectric transducers housed in roller search units that run atop the railhead" with fixed-angle probes, and that conventional inspection finds "about 90 percent" of rail flaws, leaving about 10% undetected during periodic inspection. That gap is the case made for phased array in rail.
| Rail application | Status | Source |
|---|---|---|
| Test-vehicle flaw detection (head-contact PA wheel probe) | Research prototype: tested over known defects at up to 20 mph | TTCI TD-16-030 (July 2016), TD-16-050 (Nov 2016) |
| Test-vehicle PA options from contractors and equipment makers | Advertised by at least two North American providers (2026 web pages); no independent in-service performance data found | Vendor pages (not cited as evidence) |
| Sizing rail head defects before head repair welding | Research; location needed within about ±1 in. | FRA RR 20-16 (Sept 2020) |
| Thermite (aluminothermic) weld examination | Research and simulation at FAST; recommended a 256-element portable scanner concept | TTCI TD-21-027 |
| Flash-butt weld examination in a welding plant | Required by one railway's manual (Indian Railways RDSO, revised 2022); not a US requirement | RDSO UT manual |
| Routine 213.237 testing on US main lines and transit | Conventional UT; PA not established as routine practice in published sources | 213.237; TD-16-030 |
The 2016 prototype results were promising. TD-16-050 reports:
"The prototype performed equivalent or better than a conventional UT inspection truck on every type of rail defect tested." (TTCI, Characterizing Rail Flaws Using Phased Array Ultrasound, TD-16-050, November 2016)
The same digest states the limit. Being "a head contacting inspection technique", the prototype was "unable to inspect the rail base flanges", although it could see the base under the web. It also said comparison "in the service environment" was still future work, and no later public evaluation of service performance was found for this article.
For rail welds, the practical choice is still mostly conventional 0°, 37° to 45° and 70° pulse-echo plus a hand scan of the base, with PAUT as an added or research tool. The comparison is covered in PAUT vs TOFD for rail weld inspection, with process detail in aluminothermic weld inspection and flash-butt weld inspection. How conventional rail testing works is in ultrasonic rail flaw detection.
Key takeaway: in rail, PAUT is a weld, verification and research tool in published sources, and 213.237 testing remains conventional UT.
What phased array ultrasonic testing can't do
Phased array ultrasonic testing doesn't remove the limits of ultrasound; it adds setup and data risks of its own. These limits belong in any honest comparison with conventional UT, TOFD or RT.
| Limit | Why it happens | What to do about it |
|---|---|---|
| Oversizing | Beam divergence and several focal laws seeing one reflector (ASTM E2700 1.2.1) | Size with a qualified method from the procedure; check on a reference flaw |
| Near-surface resolution | Wedge echoes and the pulse length mask the first millimeters | Use a second technique or scan from the other surface; MT or PT for surface cracks |
| Coverage gaps | A sweep from one offset leaves volume unscanned | Draw the scan plan; use two offsets or both sides |
| Focusing beyond reach | Focal depth set past the aperture's near field | Check depth against the near field after wedge deduction |
| Grating lobes and spurious echoes | Pitch too large for the wavelength or steering angle | Check probe design; verify the beam on a block |
| Coarse-grained or anisotropic welds | Beam skew and scatter in austenitic and cast structures | Apply ISO 22825-type rules; use low frequency or dual matrix arrays per procedure |
| Rail base flanges | Head-contact probes can't reach the flange tips | Hand scan the base at welds; accept the coverage limit in track |
| Setup and analysis time | Calibration of every law, encoder checks and analysis of stored data | Count them in any time comparison; scan time alone isn't productivity |
| Personnel | PAUT needs method-specific training and experience | Check the employer's written practice and any code-specific PAUT qualification |
Data volume is real. An earlier EMA calculation put 1,000 scan positions × 62 focal laws × 1,024 samples at about 127 MB of raw A-scans for one short encoded weld scan. Storage, review time and backup belong in the job plan.
Phased array also gives no special view of surfaces. Surface-breaking cracks under a weld cap or at a rail foot are better confirmed with MT or PT, and the method still needs a coupled, clean scanning surface.
Key takeaway: state oversizing, near-surface, coverage and setup limits whenever PAUT is offered in place of another method.
What should a PAUT procedure and scan plan contain?
A PAUT procedure and scan plan should let a reviewer reproduce every beam and prove the weld volume was covered. ASME V Appendix V records, as reported, include element size and pitch, focal-law parameters and wedge angle; ISO 13588 asks for a testing level; ASTM E2700 expects the technique to be shown on mockups outside its thickness range.
A Level III review would check at least these items:
- The governing documents: the technique document and edition, and the separate acceptance document.
- Probe and wedge: frequency, element count, pitch, elevation, wedge material, angle and contour for curved parts.
- Focal laws: E-scan or S-scan, angle range and step, active aperture, focal depth checked against the near field.
- Coverage drawing: weld bevel, heat-affected zone, probe offsets from each side, and the skip used.
- Calibration: velocity, wedge delay, ACG, TCG reflectors and depths, encoder tolerance and check intervals.
- Scanning: scan sensitivity, scan speed limit, data increment and how dropout is detected.
- Sizing and reporting: sizing method, how indications are recorded, and what goes to the client with the data files.
For equipment choices behind these items, see phased array ultrasonic testing equipment. For when to call an encoded scan "automated", see AUT vs PAUT.
Key takeaway: if a reviewer can't rebuild the focal laws and coverage from the documents, the procedure isn't finished.
How EMA Industries applies this
EMA Industries provides NDT Level III services from Southern California and mobilizes nationwide. For phased array work, that means Level III review of PAUT procedures and scan plans: checking focal laws against probe and near-field limits, coverage drawings, ACG, TCG and encoder steps, and that the technique and acceptance documents are named separately. Ask about a procedure or scan-plan review through our ultrasonic examination services page or contact EMA Industries.
Related reading: UT vs PAUT · AUT vs PAUT · PAUT vs TOFD for rail weld inspection · Phased array ultrasonic testing equipment · Near field vs far field in UT
Frequently asked questions
What is a focal law in phased array testing?
A focal law is the set of firing and receiving delays applied to each element in the active aperture to make one beam. A 40° to 70° S-scan at 1° steps uses 31 focal laws, and the instrument calibrates and stores each one separately.
How is PAUT different from conventional ultrasonic testing?
The sound and the reflectors are the same; the difference is beam control and recording. A phased array probe produces many angles or positions from one placement and stores them as an image, while a single-element probe gives one fixed angle and a live A-scan.
Is phased array used to test rail in track?
Only in limited ways. Published uses are research test-vehicle prototypes, vendor test-vehicle options, defect sizing research and weld examination; routine 49 CFR 213.237 testing is conventional multi-channel UT. Head-contact probes, phased array or not, can't reach the base flange tips.
What standards cover phased array ultrasonic testing of welds?
The main technique documents are ASME Section V Article 4 (with its phased array appendices), ASTM E2700-26 and ISO 13588:2019, with ASTM E2491-23 for system performance checks. None of them sets acceptance criteria; those come from the construction code, ISO 19285 or the contract.
Why do PAUT setups need angle-corrected gain?
An echo from the same reflector gets weaker as the beam angle rises, because the sound travels farther through the wedge and steel and crosses the interface less efficiently. ACG levels the response across the sweep so a 70° indication isn't under-called against a 45° one.
Sources
- ASTM E2700-26, Standard Practice for Contact Ultrasonic Testing of Welds Using Phased Arrays, ASTM International (scope and section 1.2.1, read October 2026)
- ASTM E2491-23, Standard Guide for Evaluating Performance Characteristics of Phased-Array Ultrasonic Testing Instruments and Systems, ASTM International
- ISO 13588:2019, Ultrasonic testing: Use of automated phased array technology, Genorma listing (scope and life cycle)
- ISO 23865:2021, General use of FMC/TFM and related technologies, Genorma listing
- ISO 23864:2021, Use of automated TFM and related technologies for welded joints, Genorma listing
- ASME BPVC Section V, Nondestructive Examination, ASME
- Inspection PAUT under ASME Section V Article 4, Inspenet (secondary summary of Appendix V)
- Phased array beam shaping, Evident (vendor tutorial)
- Calibration and normalization, Evident (vendor tutorial)
- ACG, Index of acronyms, British Institute of Non-Destructive Testing
- Grating lobes, TTK13 course notes, NTNU
- 49 CFR 213.237, Inspection of rail, eCFR
- TD-16-030, High-Speed Rail Flaw Detection Using Phased Array Ultrasonics, Witte and Poudel, TTCI, July 2016
- TD-16-050, Characterizing Rail Flaws Using Phased Array Ultrasound, Witte and Poudel, TTCI, November 2016
- TD-21-027, thermite weld phased array inspection study, TTCI / MxV Rail
- DOT/FRA RR 20-16, Locating and Sizing Rail Head Defects for Rail Head Repair Welds Using Phased Array Ultrasonics, FRA, September 2020
- Manual for Ultrasonic Testing of Rails and Welds (revised 2022), RDSO, Indian Railways