
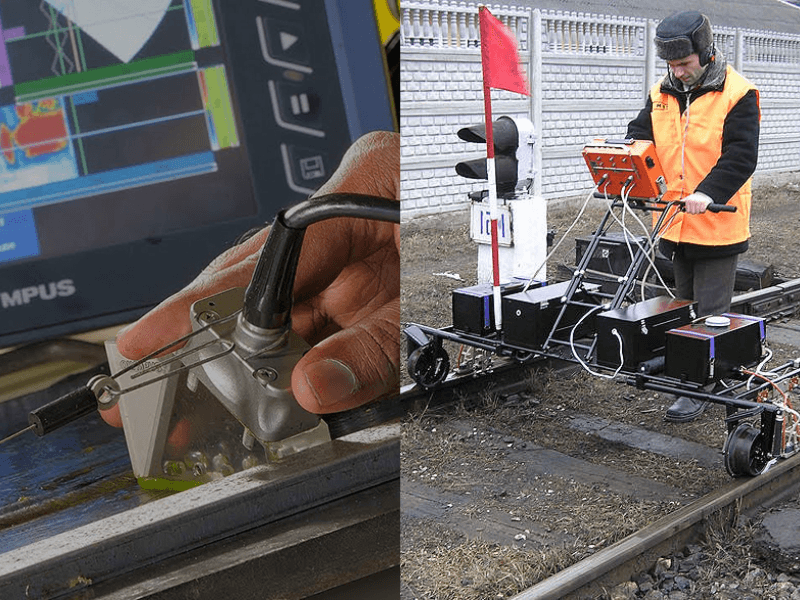
AUT and PAUT answer two different questions. Automated ultrasonic testing (AUT) describes how a scan is deployed: a scanner moves the probes, an encoder logs position and every A-scan is stored. Phased array ultrasonic testing (PAUT) describes how the beam is formed, by firing many elements with timed delays. ASTM E1961 governs zonal AUT of girth welds; ASME Section V Article 4 has separate appendices for manual and encoded PAUT.
So the two terms are not alternatives. An AUT system can carry phased array probes, conventional focused probes, a TOFD pair, or all three at once. A PAUT probe can be pushed by hand with no encoder, or mounted on a motorized band scanner as part of an AUT system. Asking "AUT or PAUT?" is like asking "a crane or steel?": one is how the work is done and the other is what it is done with.
This guide sorts the terms out, maps each code to the axis it actually governs, works through an encoded scan on a girth weld, and ends with what a buyer should write into a specification.
What is the difference between AUT and PAUT?
AUT is a deployment mode and PAUT is a beam-forming technique, so any one ultrasonic job sits somewhere on both axes at once. The first axis asks how the probe moves and what is recorded. The second asks what kind of probe generates the sound.
The confusion in many comparison pages comes from treating the two as competing products. Pipeline contractors in particular say "AUT" when they mean a complete girth-weld system, and that system very often uses phased array probes inside it. Calling the result "AUT versus PAUT" makes no technical sense.
| Conventional single-element probes | Phased array probes | TOFD probe pair | |
|---|---|---|---|
| Manual, non-encoded | Classic hand UT with an A-scan; the report records only reportable indications | Hand-held PAUT with an S-scan on screen; screen captures at best | Rare; TOFD is almost always encoded because its image is built along the scan |
| Semi-automated (encoded, moved by hand) | Encoded single-probe scans for corrosion or lamination mapping | Encoded PAUT on a hand-pushed scanner; full data stored | Encoded TOFD on a hand-pushed scanner |
| Automated or mechanized (encoded, moved by motor) | Zonal discrimination systems with many focused probes | Pipeline and vessel AUT systems using arrays to form the zones | TOFD channels added to pipeline or vessel AUT |
The table shows why buyers get mixed up. "PAUT" on its own says nothing about whether the scan was recorded, and "AUT" on its own says nothing about which beams covered the weld. A contract has to settle both.
Key takeaway: specify the deployment (manual, encoded, mechanized) and the technique (conventional, phased array, TOFD) separately.
What does "automated" mean in ultrasonic testing?
In ultrasonic testing, "automated" means that probe position is controlled or encoded and the full data set is stored, so another qualified person can review the scan later without rescanning. A motor alone doesn't make a scan automated; a recorded position and a stored data file do.
Codes and standards use three overlapping words, and the contract should say which one it means:
- Mechanized: the probes are moved by a machine, such as a motorized band or crawler. ASTM E1961 uses this word for pipeline girth welds.
- Semi-automated: an encoded scanner is moved by hand, while position and data are recorded automatically. ISO 13588 covers "semi-automated" and "fully automated" PAUT of welds.
- Automated: both movement and recording are machine-controlled. Pipeline practice uses "AUT" for the whole system, scanner, probes, instrument and software together.
The longer treatment of what AUT systems contain, and how a rail test car fits the definition, is in our article on automated ultrasonic systems. This page sticks to the distinction between deployment and technique.
What the automated label buys is evidence. A stored, encoded file lets an owner's Level III check coverage, re-evaluate an indication at a different gain, or compare a repair against the original scan. A manual report only tells you what the technician chose to write down.
What does phased array change about the beam?
Phased array changes how the beam is made: a probe with many small elements fires them with timed delays, so the beam can be steered through a range of angles and focused at a chosen depth without changing probes. It says nothing about whether the probe moves by hand or by machine.
A conventional angle-beam probe produces one fixed angle, such as 45°, 60° or 70°. A phased array probe can sweep, for example, 40° to 70° in 1° steps (a sectorial or S-scan) or step a fixed angle along the array (a linear or E-scan). Each set of delays is a focal law. The physics, focal laws and coverage geometry are explained in the difference between UT and PAUT, and what to specify for the instrument, probe and wedge is in our phased array ultrasonic testing equipment guide.
Two points matter for the AUT question:
- Phased array is a natural fit for AUT because one array can replace several conventional probes. In a girth-weld system, focal laws can be set to hit each zone of the weld bevel at the right angle and depth, a job that once needed a separate focused probe per zone.
- Phased array does not make a scan automated. A hand-held PAUT probe with no encoder produces live images on screen, but nothing ties those images to a position along the weld unless the procedure adds an encoder.
PAUT is still a pulse-echo technique. It has the same reflection physics, coupling needs and near-surface limits as conventional UT, plus some of its own, such as grating lobes and the oversizing caution ASTM E2700 raises.
What is the difference between encoded and non-encoded scanning?
An encoded scan tags every A-scan with its position along the scan axis, so the data can be rebuilt into B-, C- and D-scan views and reviewed later; a non-encoded scan shows the operator live signals that are gone once the probe moves on. The encoder, not the probe, is what turns a scan into a record.
ASME Section V Article 4 reflects this split in its phased array appendices. Secondary sources and a study guide based on the current editions describe them as follows; the numbering has changed between editions, so check the edition your contract names.
| Article 4 mandatory appendix (as reported) | What it covers | Encoded? |
|---|---|---|
| Appendix III | Time-of-flight diffraction (TOFD) technique | Yes, built along the scan |
| Appendix IV | Phased array manual raster examination using linear arrays | No: hand raster, like conventional UT |
| Appendix V | Phased array E-scan and S-scan linear scanning with linear arrays | Yes: encoded linear scan at constant standoff |
| Appendix XI | Full matrix capture (FMC), added in 2019 | Yes |
A Sonatest summary of Appendix V (October 2026) puts the encoded requirement plainly: Appendix V "requires encoded linear scanning with the probe maintained at a constant stand off from the weld." Other secondary sources report that Appendix V limits data dropout, sets an S-scan step of 1° or less and a recording increment of 1 mm or less for welds under 3 in. thick. One summary of the 2025 edition reports that the FMC requirements moved from Article 4 to Article 3. Treat all of these as leads to confirm in your edition.
| Feature | Non-encoded (manual) scan | Encoded scan |
|---|---|---|
| Position of each signal | In the operator's head and on a hand sketch | Logged by the encoder for every firing |
| Data kept | Reportable indications, perhaps screen captures | Every A-scan, unprocessed |
| Coverage proof | The operator's statement | The file shows gaps and dropouts |
| Second review | Needs a rescan | Opens from the file |
| Best use | Locating and sizing a known indication; short or awkward welds | Production welds, records a code or owner requires, repeat inspections |
Encoding does not make an examination better at finding flaws on its own. It makes the examination checkable. A badly set up encoded scan is still badly set up; it is just badly set up on the record.
Key takeaway: "encoded PAUT" and "manual PAUT" fall under different appendices and give very different records, so name which one you want.
Which codes govern AUT and PAUT?
Most documents govern one axis, either the deployment or the technique, and almost none set acceptance criteria themselves. Acceptance comes from the construction code, the pipeline standard, an engineering critical assessment (ECA) or the owner.
ASTM E1961-16(2021), Standard Practice for Mechanized Ultrasonic Testing of Girth Welds Using Zonal Discrimination with Focused Search Units, is the clearest AUT document. It is a deployment-and-technique practice for pipeline girth welds, and its scope sends acceptance elsewhere:
"Acceptance criteria are based upon flaw limits defined by an Engineering Critical Assessment (ECA) or other accept/reject criteria defined by the Contracting Agency." (ASTM E1961-16(2021), Section 1.1)
ASTM E2491-23 is a phased array document, but it governs neither the scan nor acceptance. Its scope covers "procedures for evaluating some performance characteristics of phased-array ultrasonic examination instruments and systems", for comparing systems or detecting long-term drift by periodic repetition. It "establishes no performance limits", and it states that it is not a substitute for calibration or standardization. Its apparatus does include position encoders, which makes it useful for checking an AUT system's PAUT hardware.
| Document | Axis it governs | What it does | Sets acceptance? | Confidence |
|---|---|---|---|---|
| ASTM E1961-16(2021) | Deployment and technique (mechanized zonal) | Girth-weld AUT; zones typically 2–3 mm high; normally 7–25 mm wall, 6 in. and larger pipe | No: ECA or contracting agency | High (ASTM store page) |
| ASTM E2491-23 | Technique (phased array hardware) | Performance checks of PAUT instruments and systems | No: no performance limits | High (ASTM store page) |
| ASTM E2700-26 | Technique (contact PAUT of welds) | S-scan or E-scan, 9 to 200 mm; sizing caution | No | High (ASTM store page) |
| ASTM E2373/E2373M-19(2024) | Technique (TOFD) | TOFD practice, 9–300 mm | No | High (ASTM store page) |
| ASME BPVC Section V Article 4 | Both, by appendix | Manual raster PAUT, encoded PAUT, TOFD, FMC | No: construction code does | Med (appendix content from secondary sources) |
| ISO 13588:2019 | Deployment and technique | Semi- or fully automated PAUT of welds 6 mm and thicker; no acceptance levels | No (ISO 19285 has PAUT acceptance levels) | High (scope); Med (19285) |
| DNV-RP-F118 (2019, amended 2021) | Deployment (system qualification) | Qualifying an AUT system and validating it per project, for DNV-ST-F101 Appendix E | No | High (title, edition); Med (App. E link) |
| API 1104 | Acceptance and method permission | Permits UT and mechanized UT for pipeline welds; Annex A ECA route needs height sizing | Yes | Med (secondary sources) |
| AWS D1.1:2020 PAUT annex | Technique, with encoding required | Applies when PAUT is used; encoded, recorded scans | Yes, by loading type | Med; confirm in the 2025 edition |
Two rules follow from the table. First, "per ASTM E1961" or "per ASME V Article 4" in a contract tells you how the work is done but not what is rejected. Second, a code that permits AUT almost never requires it. Washington's WAC 480-75-460 is the kind of exception that proves it: the regulator, not API 1104, requires new hazardous liquid girth welds to be inspected "by radiography or automatic ultrasonic testing in accordance with API 1104".
For PHMSA-regulated gas lines, note the edition: 49 CFR 192.7 incorporates the 21st edition (2013) of API 1104, not the current 22nd edition (2021).
How is AUT used on pipeline girth welds?
Pipeline girth welds are where AUT began and where it is most standardized: a motorized band scanner runs once around the pipe and splits the weld into thin height zones, each checked by its own probe or focal law. The method is called zonal discrimination.
ASTM E1961 describes it in Section 4.2: the weld "is divided into approximately equal vertical examination sections (zones) each being assessed by a pair of ultrasonic search units". Zones are typically 2 to 3 mm (0.08 to 0.12 in.) high, which usually calls for focused search units. Results appear as a strip chart with an amplitude gate and a time-of-flight gate per zone, so the analyst can see which zone, and which side of the weld, an indication sits in.
Where phased array comes in is the hardware. Older systems used a separate focused conventional probe for every zone. Many current systems use phased array probes, with focal laws designed for each zone of the bevel, and often add TOFD channels for height and volumetric channels for porosity. The system is still AUT; the zones are now formed electronically.
Three features make girth-weld AUT different from general-purpose encoded PAUT:
- It is set up for one bevel. The zones are designed around a specific weld preparation, so a change in bevel, wall thickness or diameter needs a new setup and a new calibration block with reflectors machined at each zone.
- It feeds height sizing. API 1104's Annex A alternative acceptance, based on an ECA, needs flaw height, which zonal AUT is designed to give. That is why ECA-based projects use AUT in practice, even though API 1104 doesn't require it.
- It is qualified as a system. Offshore projects working to DNV-ST-F101 qualify the AUT system and validate the project procedure under DNV-RP-F118, which looks at detection and sizing reliability.
Key takeaway: on a pipeline spread, "AUT" usually means a zonal system, and phased array is often the probe technology inside it.
Worked example: an encoded scan on a girth weld
For the assumed setup below, an encoded scan on an NPS 24 girth weld can run no faster than about 79 mm/s at a 1 mm recording increment, takes about 24 seconds, and stores about 122,000 A-scans. The inputs are illustrative, not from a code; they show how the deployment choice (encoded, increment, speed) and the technique choice (focal laws, offsets) depend on each other.
Inputs (assumed)
- Pipe: NPS 24, 609.6 mm (24.0 in.) OD, 15.9 mm (0.625 in.) wall, single-V girth weld. The wall falls inside ASTM E1961's normal 7 to 25 mm range.
- Technique: one phased array probe each side of the weld, each running an S-scan from 40° to 70° in 1° steps (31 focal laws per probe), plus one TOFD pair. That is 31 + 31 + 1 = 63 firings per scan position.
- Instrument: an assumed total pulse repetition frequency of 5,000 firings per second, shared across all 63 firings.
- Deployment: motorized band scanner, encoded, 1 mm recording increment, 20 mm start-stop overlap.
- Probe index offset: 30 mm from the weld centerline.
Step 1: does the S-scan reach the root and the cap?
For a beam to reach the root (the inside surface at the weld centerline) on the first leg from offset X, tan θ = X ÷ t. For the cap centerline on the second leg, tan θ = X ÷ 2t.
- Root: tan θ = 30 ÷ 15.9 = 1.887, so θ = 62.1°. Sound path = 15.9 ÷ cos 62.1° = 34.0 mm, arriving at a depth of 15.9 mm, which is the full wall and no deeper.
- Cap: tan θ = 30 ÷ 31.8 = 0.943, so θ = 43.3°. Sound path = 31.8 ÷ cos 43.3° = 43.7 mm, arriving back at the outside surface after one skip.
- Both angles sit inside the 40° to 70° sweep. The offset works only between 2t × tan 40° = 26.7 mm and t × tan 70° = 43.7 mm. Outside that window, either the root or the cap falls outside the sweep.
Step 2: how fast can the scanner move?
At 5,000 firings per second and 63 firings per position, the system completes 5,000 ÷ 63 = 79.4 positions per second. At a 1 mm increment, the maximum scan speed is 79.4 mm/s (about 3.1 in./s). Drive the band faster and the instrument can't fire every focal law at every position, which shows up as missing data lines, the dropout that encoded procedures limit.
Step 3: time and data for one weld
Circumference = π × 609.6 = 1,915.1 mm. With 20 mm of overlap the pass is 1,935.1 mm.
- Scan time at 79.4 mm/s = 1,935.1 ÷ 79.4 = 24.4 s.
- Positions = 1,936 increments + 1 = 1,937.
- A-scans stored = 1,937 × 63 = 122,031.
Step 4: what happens if the buyer tightens the increment?
| Recording increment | Max scan speed | Scan time per weld | Positions | A-scans stored |
|---|---|---|---|---|
| 1.0 mm | 79.4 mm/s | 24.4 s | 1,937 | 122,031 |
| 0.5 mm | 39.7 mm/s | 48.8 s | 3,872 | 243,936 |
Halving the increment halves the speed limit, doubles the scan time and doubles the data a qualified analyst must review. Neither scan time includes mounting the band, calibration checks on the block, or analysis, which together usually take longer than the scan itself.
What the example shows
The same phased array probes, used by hand with no encoder, would show the operator live S-scans but store none of the 122,031 A-scans. The coverage check in Step 1 is a technique question, the speed limit in Step 2 is a deployment question, and they interact through the firing count. A real scan plan also has to ray-trace the fusion faces, the heat-affected zone and transverse flaws, which is why zonal systems give each part of the bevel its own channel.
Key takeaway: a recording increment and a scan speed are not independent choices; the focal-law count ties them together.
Are AUT and PAUT used on rail and rail welds?
Rail flaw testing is a form of automated UT, but it uses fixed-angle conventional probes, not phased array; PAUT on rail is still mostly research and defect verification. Rail welds in track are inspected mainly by hand UT.
Rail flaw testing
An ultrasonic rail test car is an automated system in the deployment sense: multi-channel probe carriages, typically fluid-filled roller search units with fixed 0°, 37–45° and 70° channels, run along the rail and record signals by position. Under 49 CFR 213.240, owners may meet the 213.237 internal inspection requirement with continuous testing, where the data "must be reviewed and interpreted by a person qualified to interpret the equipment responses", and each suspect location is then field-verified. The difference between vehicle modes is covered in continuous vs stop-and-verify rail testing, and walking-speed carts in hi-rail trucks, inspection carts and walking tests.
Phased array has been trialed on rail. A TTCI research prototype (TD-16-050, 2016) fitted a phased array roller search unit in place of a conventional one, ran at up to 20 mph, and found transverse defects under shells and weld and web defects, but couldn't inspect the base flanges. An FRA report, RR 20-16 (2020), used phased array to locate and size rail head defects for head repair welding, which needs location within about ±1 in. Both are research and verification uses, not routine test-car output.
Rail welds
Thermite and flash-butt welds are normally inspected with conventional hand UT (0° and angle probes on the head, web and base) plus visual checks, to owner specifications and supplier procedures. Phased array studies on thermite welds, such as TTCI's CIVA simulation work, found that full base coverage needed a full skip using the rail as the reflector. The comparison with TOFD, and why TOFD rarely suits rail weld geometry, is in PAUT vs TOFD for rail weld inspection; weld-type detail is in aluminothermic weld inspection and flash butt weld inspection.
| Rail application | Deployment | Technique | Status |
|---|---|---|---|
| Rail flaw testing by test car | Automated, position-recorded | Conventional fixed-angle multi-channel | Routine practice under 213.237 and 213.240 |
| Rail flaw testing by walking cart | Manual or semi-automated | Conventional fixed-angle | Routine practice |
| PAUT roller search unit | Automated | Phased array | Research prototype (TTCI, 2016) |
| Head defect sizing for repair welds | Encoded, local | Phased array | FRA research (RR 20-16, 2020) |
| Thermite and flash-butt welds in track | Manual | Conventional, 0° and angle beams | Routine practice |
Key takeaway: in rail, "automated" is normal and "phased array" is the exception.
Where are they used on structural and pressure welds?
On structural steel and pressure equipment, PAUT is often deployed encoded because the governing code asks for a record, while manual PAUT is used to locate and size indications or to examine short welds. True mechanized AUT is less common here than on pipelines because weld runs are shorter and geometry changes more often.
- Structural steel (AWS D1.1). D1.1:2020 added a phased array annex. A vendor summary reports that it applies whenever PAUT is used and requires encoded, recorded scans, with its own personnel experience rules. Confirm the annex and its content in the 2025 edition before citing it. D1.1 itself doesn't require UT; the contract documents do. See AWS D1.1 weld inspection criteria.
- Pressure vessels and boilers (ASME). UT in lieu of radiography under ASME Code Case 2235 or the construction code's own rules needs recorded data and a demonstrated procedure, which in practice means encoded PAUT, TOFD, or both, done to Section V Article 4. Acceptance comes from Section VIII or the other construction code. See ASME weld ultrasonic inspection.
- Long seams and tanks. Encoded PAUT and TOFD on a motorized crawler are common on long seams, which is AUT in all but name.
When should a buyer specify AUT, PAUT, or both?
Specify encoded or mechanized deployment when you need a reviewable record or height sizing, specify phased array when you need angle coverage from limited access or imaging for characterization, and specify both for production welds that feed an ECA or replace radiography. Decide each axis on its own reason.
| If you need… | Specify the deployment | Specify the technique | Typical document |
|---|---|---|---|
| ECA-based girth-weld acceptance | Mechanized AUT, zonal | Phased array or focused conventional, often with TOFD | API 1104 Annex A, ASTM E1961, DNV-RP-F118 |
| UT in lieu of RT on a vessel | Encoded | PAUT and/or TOFD | Code Case 2235 or construction code, ASME V Article 4 |
| A D1.1 structural weld examined by PAUT | Encoded (reported annex requirement) | PAUT | D1.1 PAUT annex (confirm edition) |
| Sizing a known indication | Manual | PAUT or conventional | ASME V Article 4, App. IV or the base article |
| A short repair or awkward node | Manual | Conventional UT | D1.1 or the construction code |
| Rail flaw testing to 213.237 | Automated vehicle or manual cart | Conventional fixed-angle | 49 CFR 213.237, 213.238, 213.240 |
| Rail welds in track | Manual | Conventional | Owner specification and supplier procedure |
A specification that settles both axes should name:
- The governing code and edition, and where acceptance comes from (the code, an ECA, or the owner).
- The deployment: manual, semi-automated or mechanized, and whether data must be encoded and stored.
- The technique: conventional, PAUT, TOFD or a combination, with the technique document (ASTM E1961, E2700, E2373, or the Article 4 appendix).
- The scan plan: offsets, angles, focal laws and a ray-trace showing coverage of each part of the weld, as in the worked example.
- The recording increment and data-dropout limit, and the speed that follows from them.
- Demonstration: the reference block and reflectors, and who witnesses the setup.
- Equipment checks: E2491-type performance checks for phased array hardware and encoder calibration.
- The data deliverable: native files with a viewer, encoder and calibration records, and the indication table.
- Personnel: the employer's SNT-TC-1A or CP-189 written practice, and any method-specific experience the code adds.
- Independent review: whether an owner's Level III reviews the data, and on what sample.
Key takeaway: a contract that just says "PAUT" or "AUT per code" leaves the important half undecided.
What can't AUT and PAUT do?
Neither automation nor phased array removes the physical limits of ultrasonic testing, and each adds limits of its own.
- Automation can't fix a wrong setup. An encoded scan repeats whatever offset, gain and focal laws it is given, including the wrong ones, for the full length of the weld.
- Phased array isn't automatic full coverage. In the worked example, an offset outside 26.7 to 43.7 mm misses the root or the cap, even with a 30° sweep.
- Sizing is still uncertain. ASTM E2700 warns that "Extreme caution should be used when attempting to size indications using phased array", because beam divergence can oversize them.
- Zonal AUT is tied to the bevel. A change in weld preparation, wall or diameter needs a new setup and block.
- TOFD has dead zones near the scanning surface and at the back wall, which is why it is paired with pulse-echo or PAUT.
- Access and geometry still decide. Scanners need a continuous surface and clearance. Nozzles, branches and short welds often go back to manual UT.
- Coarse-grained and austenitic material scatters and skews the beam for any UT technique, automated or not; ISO 13588 is written for low-alloy and fine-grained steel.
- Data volume is a cost. A single girth weld in the example produced about 122,000 A-scans. A missed indication in a stored file is still a missed indication.
- On rail, fixed-angle test-car probes cover the head, web and the base beneath the web, not the base flanges, and shelling can mask defects beneath it. PAUT doesn't yet change that in routine testing.
How EMA Industries applies this
EMA Industries provides ultrasonic rail flaw testing, rail weld inspection and AWS D1.1 structural weld UT from Southern California, mobilizing nationwide. As part of our NDT Level III services, the scope can include reviewing a contractor's AUT or PAUT procedure and scan plan against the code and edition in your contract, checking the coverage and recording settings, and helping you write the deployment and technique requirements into a specification. To discuss a scope, see our ultrasonic examination services or contact EMA Industries.
Related reading
- What's the difference between UT and PAUT?
- Automated ultrasonic systems
- Phased array ultrasonic testing equipment: what to specify
- PAUT vs TOFD for rail weld inspection
- UT fundamentals: A-scan, B-scan and C-scan
Frequently asked questions
Is AUT better than PAUT?
The question compares two different things. AUT is how the scan is deployed, encoded and usually motor-driven with every A-scan stored, while PAUT is how the beam is formed. Many AUT systems use phased array probes, so the useful questions are whether you need a stored, encoded record and whether you need steered angle coverage.
Can PAUT be done manually?
Phased array can be used by hand without an encoder. ASME Section V Article 4 is reported to cover manual raster PAUT in one mandatory appendix and encoded E-scan and S-scan PAUT in another. Manual PAUT gives live images for locating and sizing, but it leaves no positional record of the weld unless the procedure adds an encoder.
What does ASTM E1961 cover?
ASTM E1961-16(2021) covers mechanized ultrasonic testing of girth welds by zonal discrimination with focused search units, mainly for oil and gas pipelines with walls normally 7 to 25 mm thick. It sets how to examine but leaves acceptance to an ECA or the contracting agency.
What is ASTM E2491 used for?
ASTM E2491-23 is a guide for evaluating the performance characteristics of phased array instruments and systems, for comparing systems or tracking drift over time. It sets no performance limits and is not a substitute for calibration, so the user or contract must state the limits and how often to check.
Do rail test cars use phased array?
Rail test cars in routine service use conventional fixed-angle probes in multi-channel roller search units, and they record data by position, which makes them automated systems. Phased array roller search units have been built and tested in research, notably a TTCI prototype in 2016, but they are not standard test-car equipment.
Sources
- ASTM E1961-16(2021), Mechanized Ultrasonic Testing of Girth Welds Using Zonal Discrimination with Focused Search Units (ASTM store)
- ASTM E2491-23, Evaluating Performance Characteristics of Phased-Array Ultrasonic Testing Instruments and Systems (ASTM store)
- ASTM E2700-26, Contact Ultrasonic Testing of Welds Using Phased Arrays (ASTM store)
- ASTM E2373/E2373M-19(2024), Ultrasonic Time of Flight Diffraction Technique (ASTM store)
- ASME BPVC Section V, Nondestructive Examination (ASME)
- Sonatest, PAUT inspection under ASME Section V Article 4 (inspenet, October 2026; vendor)
- ASME BPVC latest edition: major changes (PED Online; secondary)
- DNV-RP-F118, Pipe girth weld AUT system qualification and project specific procedure validation, 2019, amended 2021 (DNV)
- 49 CFR 213.240, Continuous rail testing (eCFR)
- 49 CFR 192.7, Incorporation by reference (eCFR)
- Washington WAC 480-75-460 (Cornell LII)
- TTCI Technology Digest TD-16-050, Characterizing Rail Flaws Using Phased Array Ultrasound, 2016 (MxV Rail)
- FRA RR 20-16, Locating and Sizing Rail Head Defects for Rail Head Repair Welds Using Phased Array Ultrasonics, 2020 (ROSA P)
- Ghaemi, API 1104 and AUT history, ECNDT 2014 (NDT.net)
- Sonatest, PAUT of welds under AWS D1.1:2020 (vendor blog, 2023)