
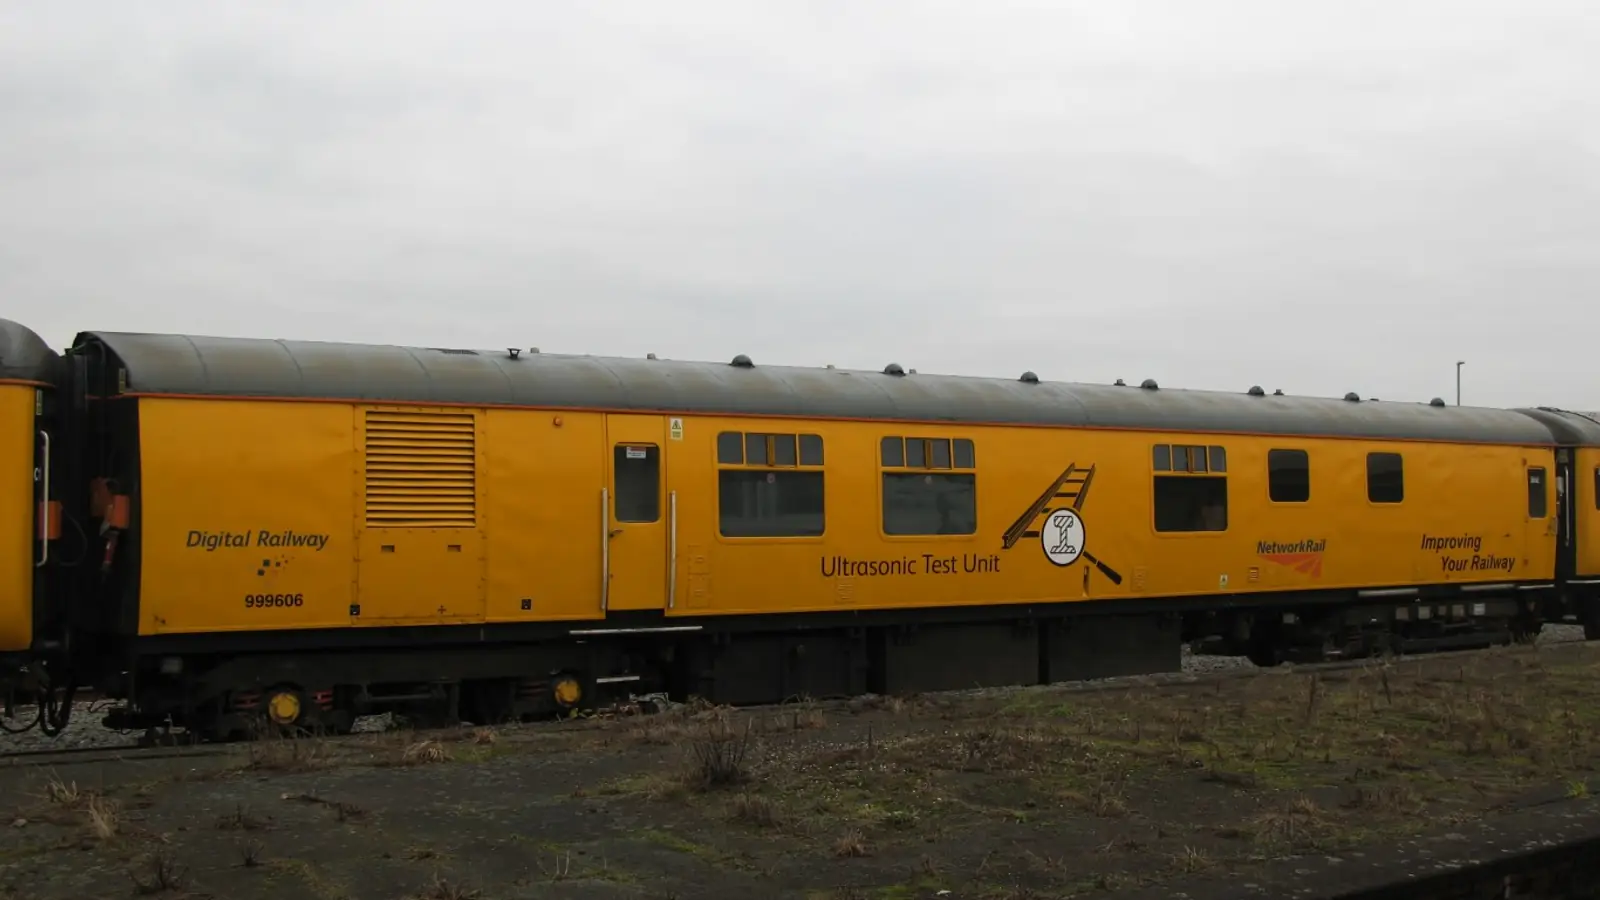
Ultrasonic rail testing capabilities cover most of the internal head and web defects named in 49 CFR 213.113, but not the whole rail. In a 1998 TTCI benchmark, six test vehicles found 72% of 49 known flaws: 96% of transverse defects larger than 20% of the head area, and only 33% of bolt hole cracks.
This page is the honest version of the capability sheet: which defects each probe channel is built to find, how often they are found in published trials, which parts of the rail a test vehicle doesn't scan, and what that means for a real segment. It is written for track engineers and short-line supervisors deciding how much to rely on a test car, and where to add hand testing.
What are the ultrasonic rail testing capabilities by defect type?
Each defect sits at a different angle inside the rail, so a test system fires several fixed beams at once and each channel is aimed at a family of defects. Typical North American systems use a 70° shear-wave channel looking forward and back for transverse defects in the head, a 0° straight beam for horizontal defects and back-wall loss, and 37–45° or side-looking channels for the web, bolt holes and the head corners. Exact channel sets vary by system and manufacturer.
The defect names below are the 49 CFR 213.113(d) definitions. Detection figures are from TTCI's 1998 benchmark (TD-99-006) where it measured them; elsewhere the rating is a qualitative engineering judgment and is labeled that way.
Capabilities matrix
| Defect (213.113(d)) | Where it starts | Main channel (typical) | Detectability by test vehicle | Main limit |
|---|---|---|---|---|
| Transverse fissure (TF) | Internal nucleus in the head | 70° forward and backward | Good: 75% of all TDs, 96% above 20% head area (TD-99-006) | Small TDs (66% at 20% head area or less) |
| Detail fracture (DF) | At or near the head surface, from shelling, head checks or flaking | 70°, often gage-side aimed | Moderate: TDs under shells about 62% vs 77% elsewhere (TD-99-006) | Masked by the shell above it |
| Compound fissure | Horizontal split head that turns up or down | 0° for the horizontal part, 70° for the transverse part | Good once the horizontal split is large (judgment) | Early stage reads as a horizontal split head |
| Horizontal split head (HSH) | Inside the head, usually 1/4 in. or more below the running surface | 0° (echo from the split, loss of back-wall) | Good: 92% (TD-99-006, two flaws) | Very small or tilted splits |
| Vertical split head (VSH) | Through or near the middle of the head | 0° loss of back-wall, side-looking channels | Good: 1 of 1 found in every run (TD-99-006) | Only one flaw in the trial; splits off-center are harder |
| Split web | Lengthwise crack along the web | 0° (web path loss), 37–45° | Fair to good (judgment) | Orientation-dependent; corrosion under crossings is missed |
| Head and web separation | Head fillet, separating head from web | 0° back-wall loss, 37–45° | Fair to good (judgment) | Joint areas, where geometry echoes crowd the trace |
| Bolt hole crack | From a bolt hole, inclined up or down across the web | 37–45° through the web, 0° | Poor to fair: 33% on two 0.25 in. cracks (TD-99-006) | Small cracks against strong hole echoes |
| Broken base and base defects | Base flange or base/web fillet | 0° covers only the base under the web | Poor: most of the base isn't scanned (TD-00-013) | Outer base flanges outside every beam |
| Defective weld | Field or plant weld; head, web or base | 70° and 0°, plus weld-specific gates | Fair: 54% on four welds of 5–15% (TD-99-006) | Weld geometry echoes; defects at the web/base fillet |
Key takeaway: rail UT is strongest on large transverse and horizontal defects in the head, weaker on bolt holes, welds and anything near or under surface damage, and close to blind in the outer base.
For defect-by-defect detail, see the guides to the transverse fissure, detail fracture, vertical split head, horizontal split head, compound fissure and bolt hole cracks.
What the definitions add
Some defect names are easy to confuse, and that matters for the matrix. Under 213.113(d)(7), a detail fracture originates "at or near the surface of the rail head" and "should not be confused with transverse fissures", which start from an internal nucleus. Under 213.113(d)(6), a defective weld is a discontinuity "exceeding 5 percent of the rail head area individually or 10 percent in the aggregate", and the rule notes that weld defects "may originate in the rail head, web, or base". A weld defect in the base is still a defective weld, even if the car can't see it.
How often does rail UT actually find defects?
Published trials put test-vehicle detection at roughly two-thirds to three-quarters of known flaws overall, rising above 90% for large head defects. No trial supports "100% detection", and Part 213 doesn't require it.
Test vehicles: TTCI TD-99-006 (1998 trials, published 1999)
TTCI benchmarked six hi-rail ultrasonic test systems from February to May 1998 on the Rail Defect Test Facility at the Transportation Technology Center near Pueblo, Colorado. The 49 flaws in the track were real defects removed from revenue service: two 0.25 in. bolt hole cracks, four defective welds of 5–15%, 40 transverse defects of 3–80%, two horizontal split heads and one vertical split head.
| Result | Detection |
|---|---|
| All 49 flaws, six runs combined | 72% (individual runs 65% to 78%) |
| Transverse defects, all sizes | 75% |
| Transverse defects of 20% head area or less | 66% |
| Transverse defects of 21% head area or more | 96% |
| Transverse defects under shells (7) vs not under shells (33) | about 62% vs 77% |
| Horizontal split heads (2) | 92% |
| Vertical split head (1) | 100% |
| Defective welds (4) | 54% |
| Bolt hole cracks (2) | 33% |
Source: TTCI Technology Digest TD-99-006, Garcia and Reiff, February 1999.
Read these numbers with their limits. The sample sizes for bolt holes, welds and split heads are tiny, so one missed call moves the rate a long way. The equipment is 1998 equipment. TTCI compared the results with the 1992 AREMA "Recommended Minimum Performance Guideline for Rail Testing" and found them in close agreement: the guideline TTCI tabulated runs from 65% for defects of 5–10% to 99% for 81–100%. That guideline's current form in the AREMA manual hasn't been checked for this page.
Handheld UT: FRA ORD-26/07 (2026)
FRA's model-assisted probability of detection study for handheld rail UT (DOT/FRA/ORD-26/07, ENSCO, July 2026) used 512 simulated responses for flaws of 1–76% head area. At a detection threshold of 0.25, the probability of detecting a 25% head-area flaw was 95.8% (mean), with a lower 90% confidence bound of 93.6%. At a stricter 0.40 threshold, the mean fell to 86.7%.
The same report found that, with a small exception, no two operators produced statistically similar calibration results. It states that "calibration errors can cause excessive false positives and false negatives". Detection is a property of the whole system: equipment, calibration, rail condition and the person reading the trace.
Key takeaway: quote rail UT detection as a rate with a size and a source, never as a guarantee.
Which parts of the rail does a test vehicle not cover?
A test vehicle scans the head and web well, the base under the web partly, and most of the base not at all. Four coverage gaps matter in practice: the base, thermite weld zones, rail under shelling, and rail where the 0° channel loses its bottom echo.
Most of the base
The beams enter through the running surface, and the base flanges sit outside every beam path. TTCI's thermite weld survey states the limit directly:
"the ultrasonic rail flaw detection process only scans the head and web of the rail, and not the majority of the base." — TTCI Technology Digest TD-00-013 (2000)
A later TTCI prototype, a head-contact phased-array system tested at up to 20 mph, found transverse defects under shells and weld and web defects but still couldn't inspect the base flanges (TD-16-050, 2016). Base cracks and base corrosion need hand UT from the base or another method. The TSB's Lakeville Road report (R19M0018) found web corrosion under a crossing that "had not been identified by the visual or ultrasonic track inspections, because the web of the rail was hidden by the crossing surface".
Thermite weld zones
Thermite welds fail where the car looks least. In the TD-00-013 survey of 265 revenue-service failures, slag and gas porosity caused 40%, and 56% of those were at the web/base fillet. Fatigue from weld-metal run-out at the web/base fillet or base caused another 32%. TTCI cautioned that its own detector-car data was likely skewed by the base coverage gap. It also found that 24.4% of the welds removed on detector-car finds showed no observable defect.
New and suspect field welds therefore need hand UT that covers the base. Plant flash-butt welds have their own trap: un-ground flashing "can cause reflections that must be distinguished from true defects" (TD-16-050). See aluminothermic weld inspection for the procedure.
Masking by shelling and head checks
A shell is a horizontal separation under the gage corner; in TTCI's heavy-axle-load tests, shells started 1/4 to 3/8 in. below the surface (TD-10-004). Sound reflects off the shell before it reaches the defect below it. That is mainly a detail fracture problem, because detail fractures start from shells. At Superior, Wisconsin, in 1992, the NTSB found that overlapping shelling cracks "prevented the penetration of the ultrasonic sound waves" to a detail fracture that a test car had passed six weeks earlier (NTSB). More on the surface conditions in rail shelling and spalling.
Loss of bottom
The 0° channel watches the back-wall echo from the base. When rolling contact fatigue, spalls, contamination or poor coupling scatter the sound, the echo drops and the system reports a no-test, called a "rail exception" in TTCI's work. FRA's RCF review says surface fatigue "prevents the successful transmission of ultrasonic waves to the base of the rail and back" (DOT/FRA/ORD-11/24).
In TTCI's grinding study, identical reflectors in the head returned an average of 67% of the control-rail response on five exception rails. Corrective grinding restored a valid test at 68 of 88 sites (77%), and at every site where at least 0.060 in. of metal was removed (TD20-002, 2020). Loss of bottom is untested rail, not a false call. It must be recorded under 213.241(c)(6) and resolved under 213.237(h). The difference is covered in false calls in rail UT.
Other gaps
| Condition | Effect on ultrasonic rail testing capabilities |
|---|---|
| Heavy gage-face wear | Fixed-angle probes inspect "the wrong volume of material" (TTCI TD-16-030) |
| Lower gage-corner fatigue cracks | "Not easily scanned by ultrasonic equipment" (NTSB RAB-16/01) |
| Cast manganese frogs | Coarse grain defeats standard UT; revenue-service checks are visual (FRA RR 22-25) |
| Rail under crossings and in embedded track | Web and base hidden; access limited |
| Joint bars | Equipment must search the rail between the bars (213.237(f)); the bars themselves aren't the target |
Key takeaway: a clean test-car report says the head and web passed a valid search. It says little about the outer base and nothing about rail listed as untested.
How fast do rail test vehicles actually test?
US test vehicles in stop-and-verify mode are commonly described as testing at roughly 15–25 mph over good rail, and slower when verifying. Including stops, average progress is far lower. Part 213 sets no test speed.
The original version of this page said both that test cars run "at operational speeds" and that high-speed systems reach only about 25 mph. The second is closer to practice. The published figures are:
| Figure | What it measures | Source |
|---|---|---|
| Up to 30 mph | Non-stop capability of late-1990s test cars | MPC 99-106 (1999) |
| 6–8 mph | Average speed including stops to hand-verify indications | MPC 99-106 (1999) |
| Usually not over 25 mph | Start/stop testing, as described in one manufacturer's introductory guide | Nordco (page since removed; treat as indicative) |
| 30–45 mph | Vendor ratings for current hi-rail and rail-bound systems | Vendor product pages |
A rated maximum isn't a working test speed. Working speed falls through special trackwork, joints, curves with surface damage and every location an operator stops to hand-verify. MPC 99-106 states that "in practice the vehicle stops frequently to hand verify indications". Ask any contractor for planned miles per shift, not top speed.
Don't confuse test speed with 213.237(h)(2). That 25 mph limit is the maximum train operating speed over rail that couldn't be validly searched.
Worked example: how many defects will one test miss?
Applying the TD-99-006 detection rates to an assumed defect population shows that a typical test leaves about one defect in four in the track.
Inputs (assumed for illustration): a 40-mile Class 4 freight segment, not a passenger or hazmat route. Before the test it holds 20 internal defects of the types the benchmark measured. The test report lists 0.6 mile as untested because of loss of bottom.
| Defect group | Count in track | TD-99-006 rate | Expected found | Expected missed |
|---|---|---|---|---|
| TDs of 20% head area or less | 10 | 66% | 6.6 | 3.4 |
| TDs of 21% head area or more | 5 | 96% | 4.8 | 0.2 |
| Horizontal split heads | 2 | 92% | 1.84 | 0.16 |
| Defective welds | 3 | 54% | 1.62 | 1.38 |
| Total | 20 | 74% (computed) | 14.86 | 5.14 |
What the numbers mean:
- About 5 of the 20 defects stay in track (5.14 ÷ 20 = 25.7% missed). Two-thirds of the misses (3.4 of 5.14) are small transverse defects, which is why the test interval exists: a small TD missed now should be found larger at the next test.
- Welds are the second-largest source of misses (1.38), and base-originating weld defects aren't in this count at all because the car doesn't scan most of the base. Treat them as unknown, not zero.
- The 0.6 mile of untested rail is 1.5% of the segment (0.6 ÷ 40). It doesn't count as inspected under 213.237(g). Before the time or tonnage limit expires, the owner must retest it, hold trains to 25 mph, or replace it (213.237(h)).
- Context from the failure-rate rule: the segment's service failure limit is 0.10 per mile per year, or 4.0 for 40 miles (213.237(a)(1)). Four or more broken rails from TFs, DFs, compound fissures or VSHs in 12 months would exceed it.
These rates come from 1998 trials on a test track with known defects. Modern equipment may do better, and shelled or worn rail will do worse (62% for TDs under shells). The method still holds: multiply each defect group by a sourced rate and plan follow-up testing for the gaps.
Is guided wave testing a substitute for a 213.237 search?
No. Guided wave UT in rail is a niche monitoring technique, not a replacement for the continuous internal search 213.237 requires.
Guided waves travel along the rail as several dispersive modes over long distances from one transducer. Their best-known rail use is broken-rail detection. A permanently installed Ultrasonic Broken Rail Detection system monitors South Africa's Sishen–Saldanha line and "detects complete rail breaks at long-range using guided wave ultrasound" (Ramatlo, Loveday, Long and Wilke, MATEC Web of Conferences, 2021). Research on the same rail shows that welds return their own guided-wave reflections, which a crack signal must be separated from (Setshedi et al., Ultrasonics, 2019).
Part 213 names no test method. It does require a "valid search", defined in 213.237(j)(4) as:
"a continuous inspection for internal rail defects where the equipment performs as intended and equipment responses are interpreted by a qualified operator as defined in § 213.238."
No published evidence shows guided wave finding small transverse defects at the head-area sizes above. Treat it as a complement for monitoring breaks, not as the scheduled internal test. Guided wave and long-range UT are the same method under two names; see guided wave ultrasonic testing.
How often does 49 CFR 213.237 require internal rail testing?
On Class 4 and 5 track, and on Class 3 track with scheduled passenger trains or a hazmat route, internal tests can be no more than 370 days or 30 MGT apart, whichever is shorter.
| Track | Maximum interval | Rule |
|---|---|---|
| Class 4 and 5 | 370 days or 30 MGT, whichever is shorter | 213.237(c) |
| Class 3 with regularly scheduled passenger trains, or a hazmat route | 370 days or 30 MGT, whichever is shorter | 213.237(c) |
| Other Class 3 | Once each calendar year (no more than 18 months apart) or every 30 MGT, whichever is longer, never more than 5 years | 213.237(c) |
| Class 1 and 2 | No 213.237 interval | 213.237(c) |
| Class 6 and higher | At least twice a year, at least 120 days apart | 213.339 |
The interval is a legal maximum, not a capability. A segment with heavy shelling, many thermite welds or a rising failure rate may need testing more often than the rule requires. Planning by tonnage is covered in how often must rail be tested, and the full rule in 49 CFR 213.237 explained. What happens after a defect is found is set by 49 CFR 213.113, summarized in FRA defect codes explained.
What ultrasonic rail testing can't do
Rail UT can't prove a rail is defect-free, can't see the outer base, and can't test through heavy surface damage. In plain terms:
- No 100% detection. Published test-vehicle rates are about 72% overall and 33–54% for bolt holes and welds in small samples (TD-99-006).
- No outer base coverage from the running surface (TD-00-013).
- No reliable view under shells or through RCF that kills the bottom echo; those stretches are untested, not passed.
- No defect sizing to code accuracy from a test car. Car calls are verified and sized by hand.
- No view of cast manganese frogs with standard UT (RR 22-25).
- No substitute for visual inspection. Visual track inspection under 213.233 is a separate requirement.
- No guarantee from a compliant interval. Meeting 370 days or 30 MGT doesn't mean every flaw was found; the service failure rate measures the outcome.
How EMA Industries applies this
EMA Industries performs ultrasonic rail flaw testing for transit agencies, short lines and industrial track owners, and rail weld inspection. We're based in Southern California and mobilize nationwide. On a capability question, the useful deliverable is a report that names the probe coverage, lists every untested stretch, and flags thermite welds and base areas that need hand UT. See our ultrasonic rail testing services, what to expect from ultrasonic railroad testing services, and our ultrasonic rail testing services in the USA, or request a quote.
Related reading: How ultrasonic rail flaw detection works · Transverse fissure in rail · Rail shelling and spalling · False calls in rail UT
Frequently asked questions
What defects can ultrasonic rail testing detect?
Rail UT is built to find the internal defects in 49 CFR 213.113: transverse fissures, detail fractures, compound fissures, horizontal and vertical split heads, split webs, head and web separations, bolt hole cracks and defective welds. It is most reliable on large head defects and least reliable on bolt holes, welds and the base.
What percentage of rail defects does ultrasonic testing find?
In TTCI's 1998 benchmark, six test vehicles found 72% of 49 known flaws, ranging from 65% to 78% per run. Transverse defects over 20% of head area were found 96% of the time, and smaller ones 66%. Treat these as dated, sample-specific figures, not guarantees.
Does ultrasonic rail testing inspect the rail base?
Only partly. The 0° beam reaches the base under the web, but TTCI states that the process scans "the head and web of the rail, and not the majority of the base". Base defects and thermite weld defects at the web/base fillet need hand UT.
How fast does a rail flaw detection car test?
Working test speeds for US stop-and-verify vehicles are commonly given as about 15–25 mph on good rail, slower when verifying. A 1999 assessment put average progress, including stops, at 6–8 mph. Vendor ratings of 30–45 mph are maximums, not working speeds.
What happens when shelling blocks the ultrasonic test?
The operator records that stretch as untested, because no valid search was made. Before the 213.237 deadline, the owner must retest it (often after corrective grinding), limit trains to 25 mph, or replace the rail.
Sources
- 49 CFR 213.237, Inspection of rail, eCFR (text read on Cornell LII, October 2026)
- 49 CFR 213.113, Defective rails, eCFR (definitions in paragraph (d))
- 49 CFR 213.339, Inspection of rail in service (Class 6 and higher), eCFR
- 49 CFR 213.233, Track inspections, eCFR
- Garcia and Reiff, Benchmarking Results of North American Rail-Flaw Detection Technologies, TTCI Technology Digest TD-99-006, February 1999
- Kristan, Thermite Weld Failure Survey, TTCI Technology Digest TD-00-013, July 2000
- TTCI Technology Digest TD20-002, corrective grinding and UT confidence, April 2020
- Bruzek, Einbinder and Tunna, DOT/FRA/ORD-26/07, MAPOD for handheld rail UT, FRA, July 2026
- Magel, DOT/FRA/ORD-11/24, Rolling Contact Fatigue: A Comprehensive Review, FRA, November 2011
- Jeffrey and Peterson, MPC 99-106, Assessment of Rail Flaw Inspection Data, Mountain-Plains Consortium, August 1999
- NTSB recommendation letter R-94-1/2 (Superior, Wisconsin, 1992)
- TSB rail investigation report R19M0018, Transportation Safety Board of Canada
- Ramatlo, Loveday, Long and Wilke, Modelling and simulation of ultrasonic inspections in welded rails, MATEC Web of Conferences, 2021
- Setshedi, Loveday, Long and Wilke, guided wave reflections from thermite welds, Ultrasonics 96 (2019) 240–252